This content was written and submitted by the supplier. It has only been modified to comply with this publication’s space and style.
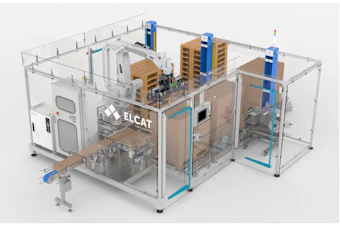
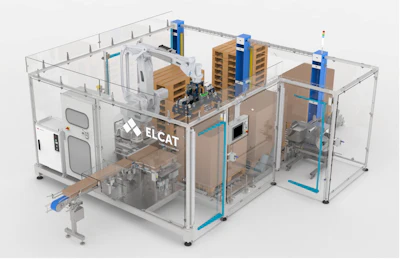
As end-of-line automation becomes increasingly important, ELCAT Food Technology is expanding its palletizing solutions with three levels of robotic automation, allowing food manufacturers to select the configuration that best matches their production requirements: from compact systems with manual pallet handling to fully automated palletizing cells.
Rather than applying the same solution to every production line, each configuration is engineered around the specific requirements of the application, including required output, available space, case dimensions, palletizing pattern and operator involvement.
The appropriate robot and pallet handling system are then selected for each project.
Three Approaches to the Same Palletizing Process
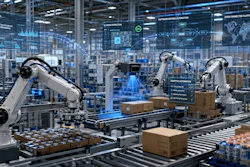
All three configurations share the same objective: receiving cases from the end of the production line and automatically building each pallet according to the programmed pattern. What changes is the way pallets are supplied, exchanged and discharged, allowing the level of pallet handling automation to be adapted to the actual requirements of each application.
From a compact Cartesian system to a six-axis robotic cell with automatic pallet management, ELCAT Food Technology configures each palletizing solution around the production process, balancing required output, available footprint and the degree of operator involvement.
 ELCAT Food Technology
Compact Cartesian Palletizing
For applications where automatic pallet handling is not required, ELCAT Food Technology offers a compact Cartesian palletizing configuration that automates case placement while keeping pallet loading and removal in the hands of the operator.
The Cartesian robot picks cases from the infeed conveyor and places them automatically according to the selected palletizing recipe, continuing the cycle until the pallet is complete. The operator then removes the completed pallet and positions an empty one for the next production cycle.
This approach provides automatic, accurate and repeatable pallet formation, making it particularly suitable where available space and the required level of automation are key considerations.
Automatic Pallet Change for Continuous Palletizing
The intermediate configuration introduces automatic pallet handling, reducing the need for operator involvement between consecutive palletizing cycles. Depending on the available space, case dimensions and required output, the system can be equipped with either a Cartesian robot or a six-axis articulated robot.
While one pallet is being filled, a second empty pallet waits in an intermediate position. Once the programmed pallet is complete, the system automatically transfers it towards the outfeed and moves the waiting pallet into the loading area, allowing the next palletizing cycle to start without manual pallet exchange.
Fully Automated Pallet Handling
At the highest level of automation, pallet supply, positioning and discharge are integrated into the robotic cell. A stack of empty pallets is loaded at the cell infeed, allowing the system to automatically prepare each pallet for the next production cycle.
A six-axis articulated robot handles the pallet and performs the programmed palletizing sequence. Once the pallet is complete, it is automatically transferred to the outfeed conveyor, while the system prepares the next empty pallet for a new cycle.
By integrating case handling with automatic empty-pallet management and completed-pallet discharge, this configuration minimizes operator involvement in the palletizing process and supports continuous end-of-line automation.
Configured Around the End-of-Line Process
Beyond the level of pallet automation, each ELCAT Food Technology system is configured around the specific end-of-line process. Robot type, gripping technology and case-handling strategy can be selected according to product dimensions, required output, palletizing pattern and available space.
 ELCAT Food Technology
Depending on the application, the system can integrate vacuum or mechanical gripping systems, as well as single or multiple case picking to achieve the required handling performance. Palletizing recipes allow different load patterns to be managed according to the production requirements.
For more automated configurations, the solution can also incorporate automatic pallet handling and interlayer-sheet management, integrating the different operations into one coordinated end-of-line process.
From Compact Palletizing to Complete End-of-Line Automation
The three configurations allow ELCAT Food Technology to adapt the level of palletizing automation to each production environment, from compact applications where pallet handling remains with the operator to integrated robotic cells designed to automate the complete process.
As part of its broader secondary packaging and end-of-line automation capabilities, ELCAT Food Technology can integrate palletizing with upstream case handling and conveying, developing coordinated solutions around the requirements of the complete production line.